Reachy Mini
Robot / hardware buildAn expressive desktop robot with separate Wireless, USB-connected Lite and simulation setup routes. [1]
Build & first use →Official website
- For
- Python and web developers building robot applications [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- Raspberry Pi
- License
- Apache-2.0 · license not fully assessed for documentation · Details by part
Overview
The v1.11.0 overview gives three setup routes. Wireless uses a Raspberry Pi CM4, battery and Wi-Fi; Lite connects by USB to a computer and uses wall power. MuJoCo simulation is a third route requiring no physical robot. These have different host and power requirements, so use the guide for the actual platform. [1] [2]
The repository offers Python control examples and points web developers to JavaScript/WebRTC applications. Apps distributed through Hugging Face Spaces are separate artifacts: the core repository snapshot does not freeze every application, model or service an app may use. [1]
Upstream estimates two to three hours to assemble a kit. That is an attributed estimate, not our measured setup time or evidence that app configuration is included. A complete delivered kit price and exact contents were not checked here. [1]
Software uses Apache-2.0, while the README assigns hardware designs Creative Commons BY-SA-NC terms without specifying the version in that statement. The software license therefore cannot establish commercial hardware-manufacturing permission. Hardware artifact scope, complete dependency preservation and our support workload remain unresolved. [1] [3]
Is this for you?
- Known limitations
- Hardware license declaration includes a noncommercial condition
- Source archive alone may omit Git LFS payloads
3D preview
Reachy Mini source visualization model. The official Reachy Mini no-collision URDF visualization at zero joint positions, using all 41 referenced source mesh assets and the complete source link hierarchy. The repository describes hardware as Creative Commons BY-SA-NC but does not identify an exact license version or file-level scope; this preview records that ambiguity and does not claim manufacturing or redistribution clearance.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP, LZMA compression) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Pollen Robotics contributors, revision 22dae6da569d888f15a73aef8fcbbe16ee95f66c. Original and preview: Hardware: CC BY-SA-NC (version unspecified); software: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Expressive desktop robot
Editorial form classification from the inspected upstream overview.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| electronics | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | available · Apache-2.0 SDK code; hardware and external applications retain separate terms. [1] [4] [3] |
| documentation | available · License not fully assessed Documentation present; embedded assets and external apps require individual reuse checks. [1] [4] [3] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 pollen-robotics/reachy_mini: README.md
Revision, date & where cited
github.com · revision
22dae6d· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 pollen-robotics/reachy_mini: commit 22dae6d
- S003 pollen-robotics/reachy_mini: LICENSE
Revision, date & where cited
github.com · revision
22dae6d· Accessed Sep 30, 2026
Used for: Overview, Source files and licenses - S004 pollen-robotics/reachy_mini: files
Revision, date & where cited
github.com · revision
22dae6d· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S009 Upstream image and reuse attribution
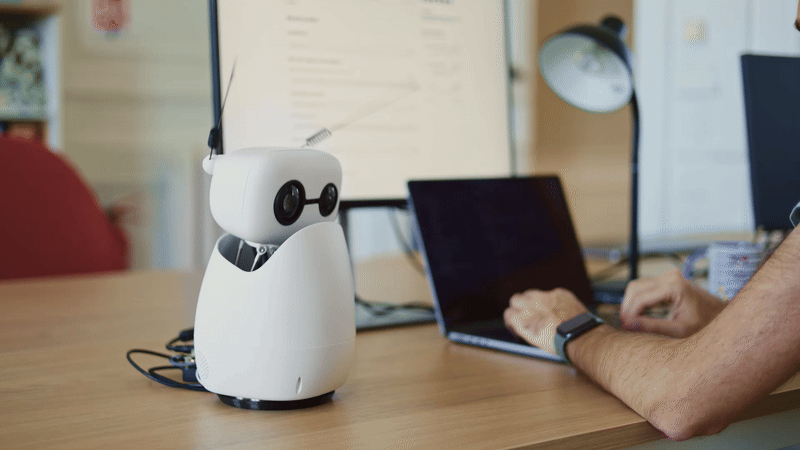
Media-only review: Still from an upstream demonstration: Reachy Mini on a desk; its hardware design files have separate terms. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
Pollen Robotics contributors · github.com · revision
22dae6d· Image SHA-256 eeaa08cd92c11329cec8e72937eaecf4ad41ca8adc56572272cdfb8d2d65020a; repository · Accessed Oct 25, 2026
Videos
- S005 Reachy Mini LITE assembly guide. (YouTube video)
Video from the project’s own channel (Pollen Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Pollen Robotics · youtube.com · Accessed Oct 4, 2026
- S006 Reachy Mini assembly guide. (YouTube video)
Video from the project’s own channel (Pollen Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Pollen Robotics · youtube.com · Accessed Oct 4, 2026
- S007 Reachy Mini Beta Assembly guide (YouTube video)
Video from the project’s own channel (Pollen Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Pollen Robotics · youtube.com · Accessed Oct 4, 2026
- S008 Pollen Robotics (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Pollen Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 4 YouTube reference(s) (S005, S006, S007, S008): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.