Teleoperate an arm
SO-101 →
Compare follower-only and leader–follower configurations, then follow the pinned build and calibration route.
Printed frame, compatible host computer and calibration on the actual arms.
Robots, end effectors and software: compare setup requirements, configuration costs and source files.
Choose by task
Selected for their documented workflows. Source researched; we have not tested these setups.
Teleoperate an arm
Compare follower-only and leader–follower configurations, then follow the pinned build and calibration route.
Printed frame, compatible host computer and calibration on the actual arms.
Start in simulation
Follow the documented introductory tutorial to build a virtual world and run a controller.
Check the supported operating system and installation requirements before starting.
Explore robot learning
Begin with an existing dataset to inspect observations and actions before choosing physical hardware.
Python and workflow-specific dependencies; training needs a separate compute budget.
241 entries · Newest published first
Source researched · Not hands-on tested
Frameworks · Software
ROS 2 and Gazebo toolkit for developing and evaluating industrial cable-insertion policies.
Tools · Software
Point-cloud evaluation tool measuring false-positive and missed collisions for configured gripper paths.
Models · Software
Research implementation for 6D object pose estimation and tracking from RGB-D inputs, using a CAD model or reference views.
Datasets · Software
Industrial-object pose-estimation dataset and evaluation toolkit, with an accessible BOP edition and conflicting license declarations.
Libraries · Software
Client APIs and developer tools for connecting to Intrinsic solutions and working with robot skills and object worlds.
Middleware · Software
ROS 2 integration for Intrinsic, including workcell-state, transform and image bridges plus skill/service build tooling.
Humanoids
A full-size humanoid mechanical-design reference with component drawings and STEP files; a complete BOM, assembly procedure and commissioned robot are not established by this review.
Arms & manipulation hardware
A bimanual teleoperation workcell with revised rail grippers, passive leader-arm gravity compensation and published parts for adapting four purchased robot arms.
Wheeled robots & hardware
A powered-caster mobile base with published fabrication files, arm mounts and phone teleoperation; complete manipulation uses a separately supplied arm.
Simulation · Software
CUDA contact-simulation research implementation for coupled stiff, soft and cloth scenes, with interactive and bounded batch execution.
Simulation · Software
Runnable libuipc examples for contact simulation, beginning with a CUDA backend check and extending to scripted robotics scenes.
Frameworks · Software
Python-embedded parallel programming language and JIT compiler for CPU/GPU numerical kernels, including physics simulation examples.
Frameworks · Software
Humanoid motion tracking and delta-action adaptation workflows, with separate simulator training and G1 policy-playback environments.
Frameworks · Software
Manager-based robot-learning framework combining Isaac Lab-style environment APIs with GPU-accelerated MuJoCo Warp.
Middleware · Software
ROS 2 Jazzy inference controller for BeyondMimic policies, using CPU ONNX inference and model-embedded motion metadata.
Frameworks · Software
MuJoCo human-motion imitation controller using SMPL-family humanoids and residual force control, with pretrained evaluation and training workflows.
Libraries · Software
SMPL-family humanoid construction and task environments for MuJoCo and Isaac Gym, with simple PPO training utilities.
Simulation · Software
Interactive MuJoCo playback of a humanoid whole-body policy with keyboard control of torso posture, velocity and optional arm motion.
Libraries · Software
Unitree robot C++ integration headers and examples linked against prebuilt SDK2 libraries for x86_64 and aarch64.
Middleware · Software
C++/Qt desktop service and SDK for XR device discovery, tracking-data callbacks and recording in teleoperation systems.
Frameworks · Software
Unitree G1 motion tracking and PICO teleoperation pipeline with Redis communication, bundled ONNX controllers and separate retargeting setup.
Models · Software
Recover human motion in world coordinates from video, with CUDA inference and noncommercial research source terms.
Libraries · Software
Differential inverse kinematics in Python using MuJoCo, with task costs, joint limits and explicitly configured collision constraints.
Frameworks · Software
Reconstruct human motion and scenes from monocular video, retarget motion to humanoids, and train scene-conditioned control policies.
Tools · Software
Estimate human body and hand motion from Project Aria camera and SLAM recordings, with separate visualization, inference and training workflows.
Frameworks · Software
Lifelong robot-learning benchmark with manipulation task suites, demonstrations and imitation-learning baselines; dataset license declarations differ across hosts.
Simulation · Software
CUDA-accelerated C++ and Python simulation library coupling rigid and deformable objects through Incremental Potential Contact.
Libraries · Software
Python kernel compiler for physics and robotics workloads, with platform-specific CPU and GPU backends and no promised Taichi backward compatibility.
Frameworks · Software
BeyondMimic motion-tracking training extension for Isaac Lab, with G1 tasks and a WandB motion registry workflow.
Frameworks · Software
Unitree G1 whole-body imitation system with teacher/student training, a supplied tracking checkpoint and separate motion-sender and controller processes.
Frameworks · Software
Physics-based humanoid motion imitation in simulation, with distinct policy configurations for tracking and fall recovery.
Middleware · Software
Python binding to Unitree SDK2 with a C++ communication backend and a G1 control example.
Tools · Software
Human-to-humanoid motion retargeting toolkit with robot-specific mappings, MuJoCo visualization and saved motion output.
Libraries · Software
Sparse constrained least-squares solver in JAX, with non-Euclidean variables and examples for geometric optimization.
Simulation · Software
Community manipulation environments for robosuite, used by MimicGen for Kitchen and Hammer Cleanup; the reviewed snapshot has legacy dependencies and incomplete example documentation.
Simulation · Software
Genesis World, formerly Genesis, is a Python simulation platform combining multiple physics solvers, robot interfaces and rendering backends; optional features have different platform requirements.
Frameworks · Software
Humanoid policy deployment framework with MuJoCo and robot-specific adapters; the reviewed release has conflicting license labels that require clarification.
Frameworks · Software
Motion-imitation reinforcement-learning framework with DeepMimic, AMP, ASE and ADD implementations; simulator setup and external motion assets are separate requirements.
Tools · Software
LIBERO evaluation extension that perturbs objects, positions, language, task goals and environments to study policy generalization in simulation.
Libraries · Software
Python toolkit for differentiable robot kinematics, inverse kinematics and trajectory optimization, with JAX acceleration and explicit joint and collision-model limits.
Tools · Software
Source-available tool for generating robot demonstrations from a small human dataset; code is limited to noncommercial research/evaluation, while released datasets use CC-BY-4.0.
Frameworks · Software
Humanoid motion-learning framework with backend-specific training and pretrained tracking policies; model, dataset and robot-asset terms are separate from the source-code license.
Libraries · Software
CUDA-accelerated motion planning library for robot kinematics, collision checking and trajectory optimization; the reviewed v0.8.0 release introduces the V2 API.
Frameworks · Software
Coding-agent framework for developing reusable robot manipulation skills in simulation, with a separate documented YAM hardware workflow.
Wheeled robots & hardware
Printable three-wheel mobile base with a motorized lift and two AM-ARM200 arms, run as a Raspberry Pi 5 host with a PC client through the lerobot_alohamini fork.
From USD 950.00 upstream estimate
Arms & manipulation hardware
Printable 6+1 DoF leader/follower arm pair using Feetech STS3215 and STS3095 servos, with LeRobot support supplied through the separate lerobot_alohamini fork.
From USD 144.44 upstream estimate
Leg subassembly
Twelve-actuator bipedal leg set (lower body only) with articulated toes and a two-motor RSU ankle, published as STL simulation meshes, an MJCF model and an LFS-stored STEP assembly.
Sensor component
Open-hardware biopotential analog front-end board (2.54 × 1.00 cm) for ECG, EMG, EOG and EEG acquisition with a 5 V microcontroller ADC; a sensor component with EMG servo and claw-control example sketches, not a robot.
From USD 69.00 vendor price
Aerial robots
Teensy 4.0 quadcopter taught step by step in a 222-page build and programming manual, with a PCB upper frame and separate per-chapter Arduino code repositories; manual and code are licensed CC BY-NC-SA 4.0.
Aerial robots
Sub-250 g collision-resilient quadcopter with a bamboo or carbon-rod frame joined by printed TPU parts, an INAV flight controller and a Raspberry Pi Zero W controlled through the MIT-licensed cognifly-python library; no license file was identified for the frame files.
About CAD 407.90 upstream estimate
Arms & manipulation hardware
Open controller electronics, FPGA firmware and cisst/SAW software for research systems built from retired da Vinci arms and consoles; the arms themselves are supplied hardware, not an open design.
Aerial robots
ESP32 quadcopter with a 3D-printed frame, four brushed motors switched by MOSFETs, an SPI IMU board, Arduino firmware with Wi-Fi/MAVLink control and a Gazebo simulator; no repository license file was identified.
Other robotics hardware
Pollen Robotics handheld demonstration recorder (Raspberry Pi 4, fisheye camera, OAK-D SR, finger angle sensors) with an offline SLAM pipeline that exports LeRobot datasets.
About EUR 585.03 upstream estimate
Haptic peripheral
Fingertip-worn haptic device that rotates one linear resonant actuator with a Dynamixel servo to render 2D directional cues during robot teleoperation; printable parts, an editable source design and a priced BOM are released, but no control code was identified.
About USD 241.12 upstream estimate
Wheeled robots & hardware
200 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors and a choice of hobby LiDARs, run through the shared Kaia.ai ROS 2 stack; sized for common 220 mm-class printers.
About USD 66.00 upstream estimate
Wheeled robots & hardware
300 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors, a 360-degree LiDAR and a phone or tablet head, run through the shared Kaia.ai ROS 2 stack; pet character and skills are upstream work in progress.
About USD 199.60 upstream estimate
Aerial robots
3D-printed tricopter/flying-wing VTOL with two tilting front motors and a fixed rear motor, tuned on ArduPlane; STL/3MF artwork and parameter files are licensed CC BY-NC-SA 4.0 and native CAD is withheld.
Teleoperation input
Unpowered 3D-printed six-joint leader arm read by AS5600 encoders through an ESP32, used to teleoperate an SO-ARM follower in MuJoCo or through LeRobot.
About INR 2,619.00 upstream estimate
Wheeled robots & hardware
Differential-drive AMR base with a sheet-metal chassis, Raspberry Pi 5, Teensy 4.0, two 60 W ZD BLDC gearmotors, RPLIDAR A1 and ROS 2 Jazzy; upstream discloses open safety gaps such as no battery fuse or hardware E-stop.
Robotic hands · End effector
Single-actuator, tendon-driven anthropomorphic hand design from the OpenBionics initiative, with 3D-printed and laser-cut variants, parametric SolidWorks CAD and a 2015 assembly report; repository-wide CC BY-SA 4.0 statement.
Sensor component
DIY triangulation scanning laser rangefinder (STM32F030, TSL1401CL line sensor, 780 nm laser, slip-ring head) rated by its author at 5 scans/s, 2-degree steps and up to 4 m; a sensor component for robots, not a robot.
About USD 23.17 upstream estimate
Models · Software
Deep-learning visual navigation engine for the Crazyflie 2.1 nano-drone: PyTorch CNNs, quantization and deployment flow for the AI-deck GAP8 processor, onboard flight application and a collected dataset; code Apache-2.0, v3 dataset CC BY-NC-SA 4.0.
Arms & manipulation hardware
Seeed Studio 6+1 DoF desktop arm with CNC aluminium and printed parts, published as B601-DM (Damiao motors, 24 V) and B601-RS (RobStride motors, 48 V) under CERN-OHL-W-2.0 hardware terms.
About USD 1,436.40 vendor price
Humanoids
Full-size DIY humanoid prototype from RoboParty with CNC-machined metal structure, 23 Damiao actuators in the published BOM, ROS 2 deployment and Isaac Lab training code; V2.0 hardware is not compatible with V1.0.
About CNY 49,743.53 upstream estimate
Legged robots & hardware
Small 3D-printed ESP32 quadruped with eight MG90S servos, an OLED face and Wi-Fi control; four controller-board routes need matching firmware pin settings.
About USD 50.00 upstream estimate
Other robotics hardware
Room-scale four-line cable robot (Arpeggio hardware) with two corner anchors and a hanging camera gripper, driven by a host-run Python motion controller; a public prototype.
From USD 655.00 upstream estimate
Humanoids
Small 3D-printed humanoid using sixteen Feetech serial-bus servos and a Milk-V Duo S; the main repository is now a pointer, so the BOM and STLs come from the separate docs repository.
About USD 350.00 upstream estimate
Motor controller
OpenESC-20x20 is a four-channel brushless motor controller with available KiCad sources and unresolved differences between headline ratings and technical test notes.
Tendon-driven dexterous robotic hand
BiDexHand V4 is a 16-DoF tendon-driven hand with printed parts, a Servo2040 PWM route and ROS 2 control packages.
Six-legged servo hexapod
Printed 18-servo hexapod with separate mechanical designs, Servo2040 firmware and a Raspberry Pi controller.
Leg subassembly
Modular knee-and-ankle research platform with published assembly documentation, externally hosted design downloads and a separately licensed Python SDK.
Aerial robots
ESP32-based educational quadcopter with a documented S2 V1.2 build and sensor-dependent assisted flight modes.
Six-legged servo hexapod
Historical six-legged servo robot with available frame designs, Servotor32 control sources and a Python 2-era host application.
Wheeled robots & hardware
Raspberry Pi camera and relay subsystem for targeted weed treatment, with printable enclosures and configuration-specific wiring requirements.
Motor controller
Open brushless servo-controller designs with CAN-FD control, board-specific electrical limits and motor calibration requirements.
Motor controller
Legacy dual-axis brushless motor control with public v3.x firmware; v3.6 board designs and newer-generation firmware have different openness boundaries.
Control board
ROS-oriented STM32F7 controller with Arduino firmware sources and separate REVH hardware files whose precise reuse license remains unresolved.
Actuator component
Brushless belt-reduced research actuator core with a v1.1 prepared encoder-kit route, precision printing requirements and separately integrated motor control.
Arms & manipulation hardware
TriFingerEdu v1 is a nine-axis torque-controlled manipulation platform built from three FingerEdu modules, with a documented TI evaluation-board control route.
Arms & manipulation hardware
Nine-axis three-finger manipulation benchmark with a separately instrumented object. Historical v0.9 hardware and legacy software requirements are scoped separately.
Legged robots & hardware
Twelve-axis quadruped benchmark with Dynamixel actuation and external-tracking support. Historical v0.9 hardware and legacy software requirements are scoped separately.
Arms & manipulation hardware
Motorized printed microscope with an RMS-objective build route, separate controller and software dependencies, and explicit beta-version compatibility limits.
Arms & manipulation hardware
Programmable laboratory liquid handler with a dedicated OT-2 software route, published customization files and configuration-specific calibration requirements.
Teleoperation input
Joint-matched teleoperation leaders for robot manipulators; selected coverage follows the YAM passive configuration and distinguishes the separate Franka FR3 ROS 2 workflow.
Arms & manipulation hardware
Printed rotary pendulum with Arduino Nano control and a MuJoCo-to-hardware learning pipeline; preserved sources include rig-specific distilled policy weights and differing bring-up microstep guidance.
Arms & manipulation hardware
Handheld gripper-based demonstration collection and diffusion-policy workflow, with separate robot deployment hardware and explicit SLAM, timing and source-artifact gaps.
Wheeled robots & hardware
Small wheeled research robot; this profile covers e-puck2 using its official hardware guide, pinned Qt monitor and separately preserved STM32F407 firmware sources.
Controller extension
Raspberry Pi extension for e-puck and e-puck2 robots, with Linux integration, separate controller firmware and an optional YRL expansion board.
Wheeled robots & hardware
Educational wheeled robot; this profile selects Thymio II PCB version 2.1 design sources and separately preserved V14 firmware, with explicit generation and dependency boundaries.
Wheeled robots & hardware
DIY robotic mower reference platform; this review selects the 1.0a10-Azurit release and records its PCB configuration, stored-setting behavior and conflicting license notices.
Wheeled robots & hardware
RTK-guided mower conversion ecosystem; this review selects the v2 YardForce route and preserves its separate carrier-board and xCore firmware revisions.
Wheeled robots & hardware
Experimental agricultural robot integration stack using ROS 2 Jazzy, ESP32/Lizard control and RTK GNSS; the selected sources distinguish Gazebo mission results from incomplete hardware validation.
Wheeled robots & hardware
Precision farming rover with separate software, electronics and mechanical sources; the documented Docker simulation substitutes fake sensor data and is not evidence of field performance.
Arms & manipulation hardware
Track-mounted gardening robot with a moving gantry and interchangeable tools; this profile selects FarmBot Genesis v1.8 documentation and distinguishes the standard and XL installations.
Wheeled robots & hardware
Agricultural weeding rover with published prototype V3 design files and an adapted CNC weeding tool; unfinished electronics and steering details require configuration work.
Marine robots
Commercial underwater ROV with published integration CAD and open software; this profile selects the standard six-thruster R4 configuration and distinguishes it from the Heavy upgrade.
Marine robots
Research autonomous underwater vehicle with Pixhawk, Raspberry Pi and Jetson TX2; this review selects the documented LoCO 1.0 configuration and separates later internal structure alternatives.
Marine robots
Historical DIY underwater exploration platform; this entry selects the OpenROV 2.8 mechanical files and the corresponding named controller-board package for source research.
Aerial robots
Research aerial manipulator combining a six-motor flying platform with a two-link torque-controlled extremity and an external motion-capture setup.
Aerial robots
Educational quadrotor platform pairing a PX4 flight controller with Raspberry Pi and ROS; this entry selects Clover 4.2 construction and the documented ROS Noetic image route.
Aerial robots
Small quadrotor development platform; this profile selects the brushed Crazyflie 2.1 hardware and distinguishes its firmware target from Brushless and Bolt variants.
Aerial robots
Laser-cut quadrotor frame for carrying a smartphone or compact camera; the preserved frame files and original Spanish manual leave complete software and electronics reproduction unresolved.
Wheeled robots & hardware
Two-arm mobile manipulator with a three-wheel omnidirectional base, released printable parts and a modified LeRobot control repository.
Two-wheel inverted-pendulum balancing robot.
Two-wheel balancing robot with ROS 1 control and Gazebo simulation sources; physical construction uses custom motor drives, a Pi CAN shield and power distribution board.
Wheeled robots & hardware
Small modular robot with a PCB chassis, ESP32-S3 and two- or four-wheel variants; separate Microblocks, MicroPython and ROS 2 routes have different maturity.
Wheeled robots & hardware
Two-wheel balancing robot project using a Raspberry Pi, pi3hat and moteus motor controllers, with printed parts and source-defined balance settings.
Wheeled robots & hardware
Raspberry Pi mecanum robot with ROS 2 navigation using lidar and an IMU; its published wheel commands are not measured wheel speeds.
Wheeled robots & hardware
Three-wheel mobile manipulator with SO-100/SO-101 arm options, printed parts and a separate LeRobot teleoperation stack.
From USD 546.97 Known US parts subtotal · Oct 4, 2026
Wheeled robots & hardware
Hardware-and-software platform combining two leader arms, two follower arms and an AgileX Tracer base for whole-body teleoperation and demonstration collection.
About USD 31,757.86 upstream estimate
Wheeled robots & hardware
Small tracked Jetson robot; this profile covers the preserved 1.5.1 source, whose container recipe targets ROS 2 Foxy and whose STL files carry noncommercial terms.
Wheeled robots & hardware
Research vehicle conversion built around a specific mobility scooter, with Arduino throttle control, actuator steering and a legacy ROS/Gazebo stack.
Wheeled robots & hardware
Four-wheel mobile base built from aluminum extrusions, with a documented articulated chassis, radio control and encoder-based motor control.
Wheeled robots & hardware
Small Jetson Nano educational robot with printed chassis and browser-based control; the reviewed 0.4.3 build uses legacy Nano-specific images and matched wheel/caster parts.
Wheeled robots & hardware
Mobile robot base with available ROS host software; the reviewed setup follows separately preserved Noetic sources, with unreleased controller firmware and revision-specific hardware constraints.
Wheeled robots & hardware
ROSbot 2R mobile platform with separately versioned ROS packages and CORE2 microcontroller firmware; this entry distinguishes the 2R configuration from newer ROSbot hardware.
Frameworks · Software
GPU-accelerated robot-learning framework; the reviewed 3.0 early-access release introduces multiple physics backends and changed installation and migration workflows.
Models · Software
Transformer diffusion robot policies with pretrained checkpoints and fine-tuning tools; observation history, action statistics and robot-specific interfaces must match the selected model.
Models · Software
Vision-language-action model code, checkpoints and adaptation examples for pi0, pi0-FAST and pi0.5, with backend-specific features and robot-specific action conventions.
Frameworks · Software
Robot-learning-from-demonstration framework with HDF5 dataset tooling, offline learning algorithms and version-specific simulation datasets.
Simulation · Software
MuJoCo-based robot-learning environments with configurable robots, grippers, controllers and observations; the reviewed v1.5.2 setup requires matching rendering and action conventions.
Wheeled robots & hardware
Python RC-car platform for manual driving and optional learned control; reviewed Raspberry Pi/PCA9685 build guidance has OS-version conflicts and an incomplete parts budget.
Wheeled robots & hardware
Ackermann-steered racing research platform; the preserved Xavier NX/Slash guide differs from its newer Orin Nano Super/Fiesta parts list and requires configuration-specific calibration.
Wheeled robots & hardware
Configurable ROS 2 mobile-robot stack; this profile selects a two-wheel differential-drive, ESP32 control route with separately versioned firmware and measured chassis parameters.
Wheeled robots & hardware
RC-based research racecar; the reviewed Nano route uses V3 printed parts and separately versioned ROS control packages, with older firmware/image assumptions requiring validation.
Wheeled robots & hardware
Six-wheel printed rover with separately preserved build files and ROS software; the reviewed default software uses ROS Melodic and requires per-robot calibration.
Wheeled robots & hardware
Six-wheel rocker-bogie rover with off-the-shelf mechanical parts and separate ROS control software; reviewed hardware and software snapshots need version and calibration reconciliation.
Wheeled robots & hardware
Smartphone-controlled wheeled robot platform; the reviewed DIY configuration combines an Arduino Nano and L298N driver, with phone and firmware requirements distinct from the advertised body cost.
Wheeled robots & hardware
ROS 2 mobile research platform on an iRobot Create 3 base, with distinct Standard/Lite sensor packages and distribution-specific base-firmware requirements.
Legged robots & hardware
Underactuated bar-swinging research robot with one QDD actuator, passive hooks and simulation/control sources; requires a ladder test rig, and the reviewed hardware script conflicts with its guide.
Legged robots & hardware
Twelve-servo Raspberry Pi/Arduino quadruped with downloadable CAD and Python gait code; hardware is noncommercial source-available and manual calibration is required.
Printed quadruped with three joints per leg.
Twelve-servo printed quadruped prototype with CAD, PCB files and ROS control sources; calibration, gait refinement and build instructions remain incomplete.
Wheeled robots & hardware
Reaction-wheel unicycle research platform, scoped to v2.5 CAD and firmware with a documented state-estimation error and historical development tools.
Simulation · Software
C++ and Python toolbox for multibody dynamics, mathematical optimization and model-based robot control, with installation choices tied to platform and solver requirements.
Simulation · Software
Robot simulation library and application with physics, sensors and plugins; Jetty setup and ROS integration require matching package and distribution choices.
Frameworks · Software
Libraries and tools for robot applications, reviewed through a Humble release manifest and version-matched documentation for installation and node communication.
Simulation · Software
Robot simulation environment with a scene editor, sample worlds and controller APIs; reviewed at R2025a with release-specific graphics requirements and asset licensing.
Legged robots & hardware
Original Mini Pupper quadruped with twelve custom servos, Raspberry Pi hardware and separate movement/ROS stacks; hardware generation, image and calibration route must be matched.
Legged robots & hardware
Quadruped source collection with distinct A1 and A2 configurations, printable structural parts, C++ control and browser-based simulation; this review centers on the documented A1 operating configuration.
Legged robots & hardware
Nybble/Bittle robot-family entry centered on OpenCat 1.2.5 NyBoard firmware, calibration and host tools; software openness does not establish complete frame or electronics manufacturing sources.
Biped with five controlled joints per leg.
Ten-joint biped with purchased actuators, machined and welded metal parts, and a ROS 1 learning-to-control workflow; external hardware rights and build completeness need separate checks.
Legged robots & hardware
Twelve-joint quadruped with purchased actuators and fabricated metal parts; its preserved ROS 1 control snapshot warns that the supplied policy is not very stable.
Desktop biped with two three-axis legs.
Printed desktop biped with four custom torque actuators, two positioning servos and a shared Python simulation/hardware interface; controller-source licensing remains unresolved.
Humanoids
Humanoid design and one-leg benchmark exploring low leg inertia through belts and parallel linkages; the maintainer has put the project on hold.
Humanoids
Ten-degree-of-freedom research biped with machined aluminum parts, EtherCAT motor control and learned locomotion; artifact and dependency licenses need separate checks.
Humanoids
Printable humanoid with FreeCAD sources, a Servo 2040 control route and MuJoCo examples; power selection and several servo mappings remain unresolved.
Legged robots & hardware
Wheeled balancing robot with articulated servo legs, Arduino balance firmware and Raspberry Pi inverse-kinematics examples; electronics and controller integration remain incomplete.
Simulation · Software
Physics engine for articulated mechanisms and contact, with C/Python interfaces and a version-sensitive model and simulation workflow.
Frameworks · Software
ROS 2 navigation framework with configurable bringup, localization and behavior-tree navigation; robot and distribution matching are essential.
Frameworks · Software
ROS 2 framework for managing controllers and hardware interfaces, with mock components for checking integration before physical hardware trials.
Middleware · Software
Bridge that exposes position-controlled ros2_control arms as Intrinsic ICON hardware modules.
Libraries · Software
C++ shared-memory transport and real-time utilities used by the ICON control framework.
Frameworks · Software
Preview framework for managing model-serving lifecycles and exposing inference services to ROS 2.
Tools · Software
MoveIt planning services and client skills for Intrinsic Core, with a documented offline mock-hardware route.
Middleware · Software
ROS camera adapters with documented Orbbec, Luxonis, Zivid and experimental Ensenso integration routes.
Libraries · Software
C++ allocation monitor for detecting heap operations inside designated real-time sections.
Legged robots & hardware
Wheeled biped with four leg servos, two driven wheels and a Raspberry Pi control stack; the reviewed build guide needs revision matching.
Frameworks · Software
Local robotics runtime, SDK and real-time control framework with a documented machine-tending simulation route.
Tools · Software
Configurable CNC machine-tending reference application using Intrinsic Core, behavior trees, perception and machine I/O.
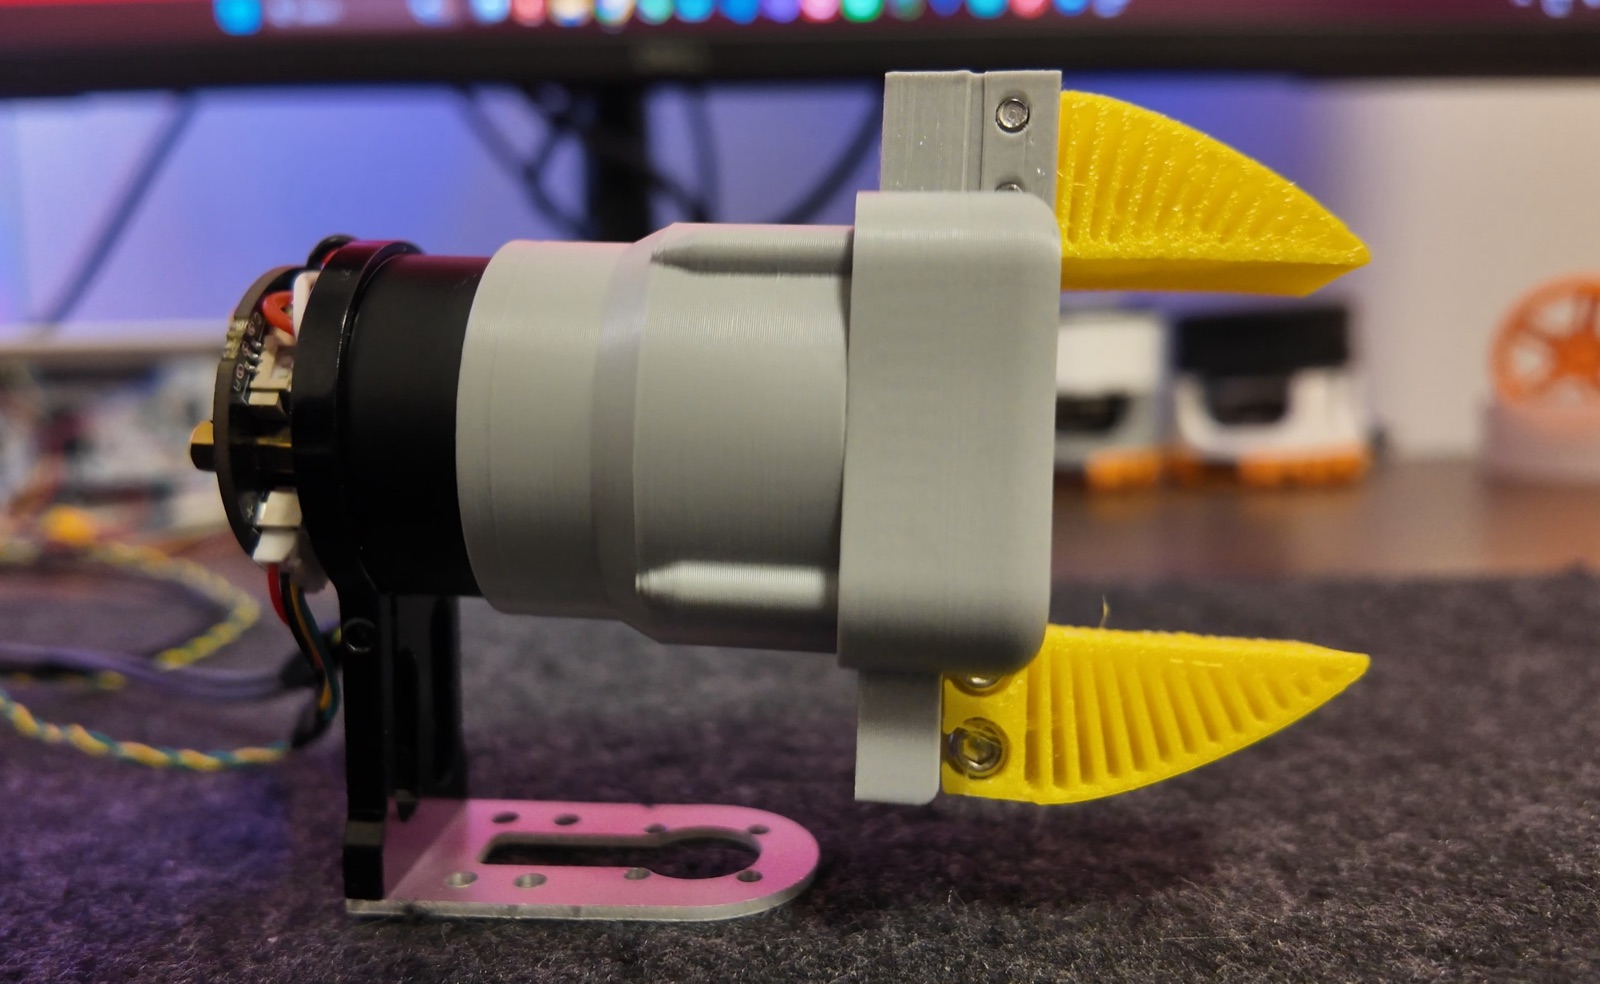
Compact rack-driven parallel gripper · End effector
Compact rack-driven gripper with an assembly STEP and upstream build photo; exact actuator, BOM and control integration still need to be specified.
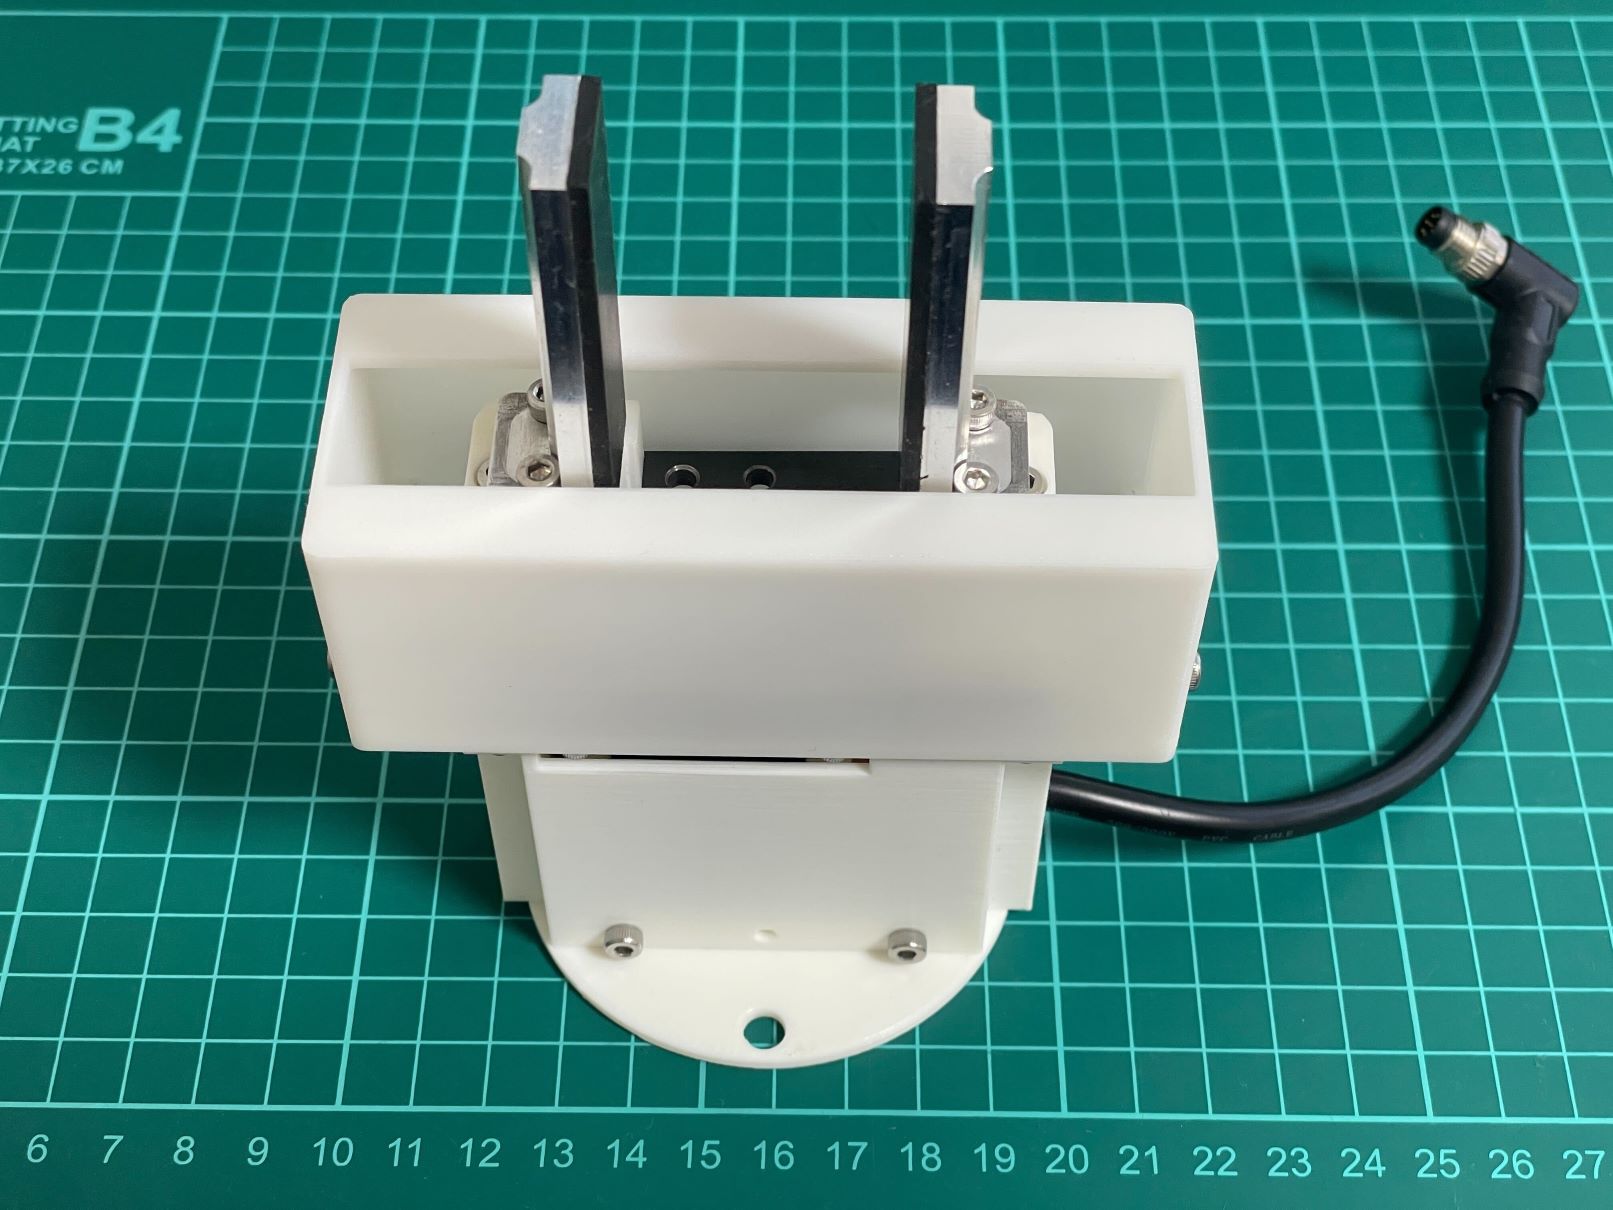
Rack-driven parallel gripper for LITE 6 · End effector
Parallel-jaw gripper for the LITE 6 using a Dynamixel XL330 servo, printed housings, machined claws and OpenRB control examples with a serial-rate mismatch to resolve.
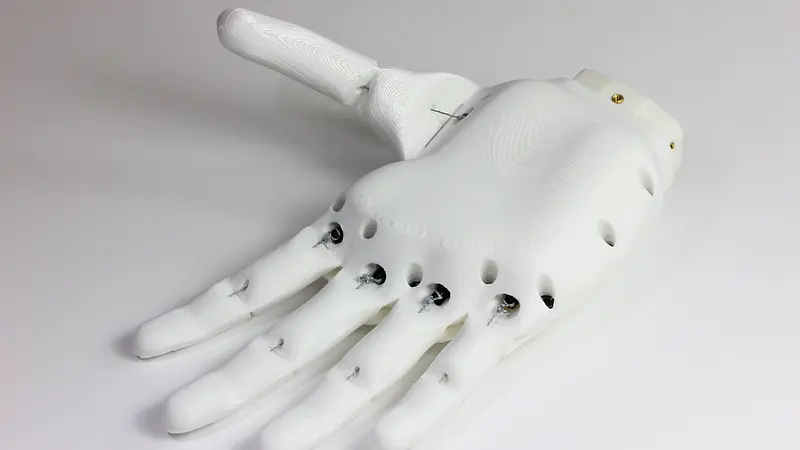
Five-finger robotic development hand · End effector
Five-actuator robotic development hand with a flexible printed palm, rigid covers and separate Almond controller and Artichoke firmware sources.
Planetary-geared filament feeder · End effector
Planetary-geared filament feeder for a Stealthburner toolhead, with custom gearbox parts, selectable printed housings and a detailed assembly manual.
Magnetic tool coupling · End effector
Experimental printer tool changer that rotates permanent-magnet rings to attach lightweight tools; requires custom docks and Klipper configuration.
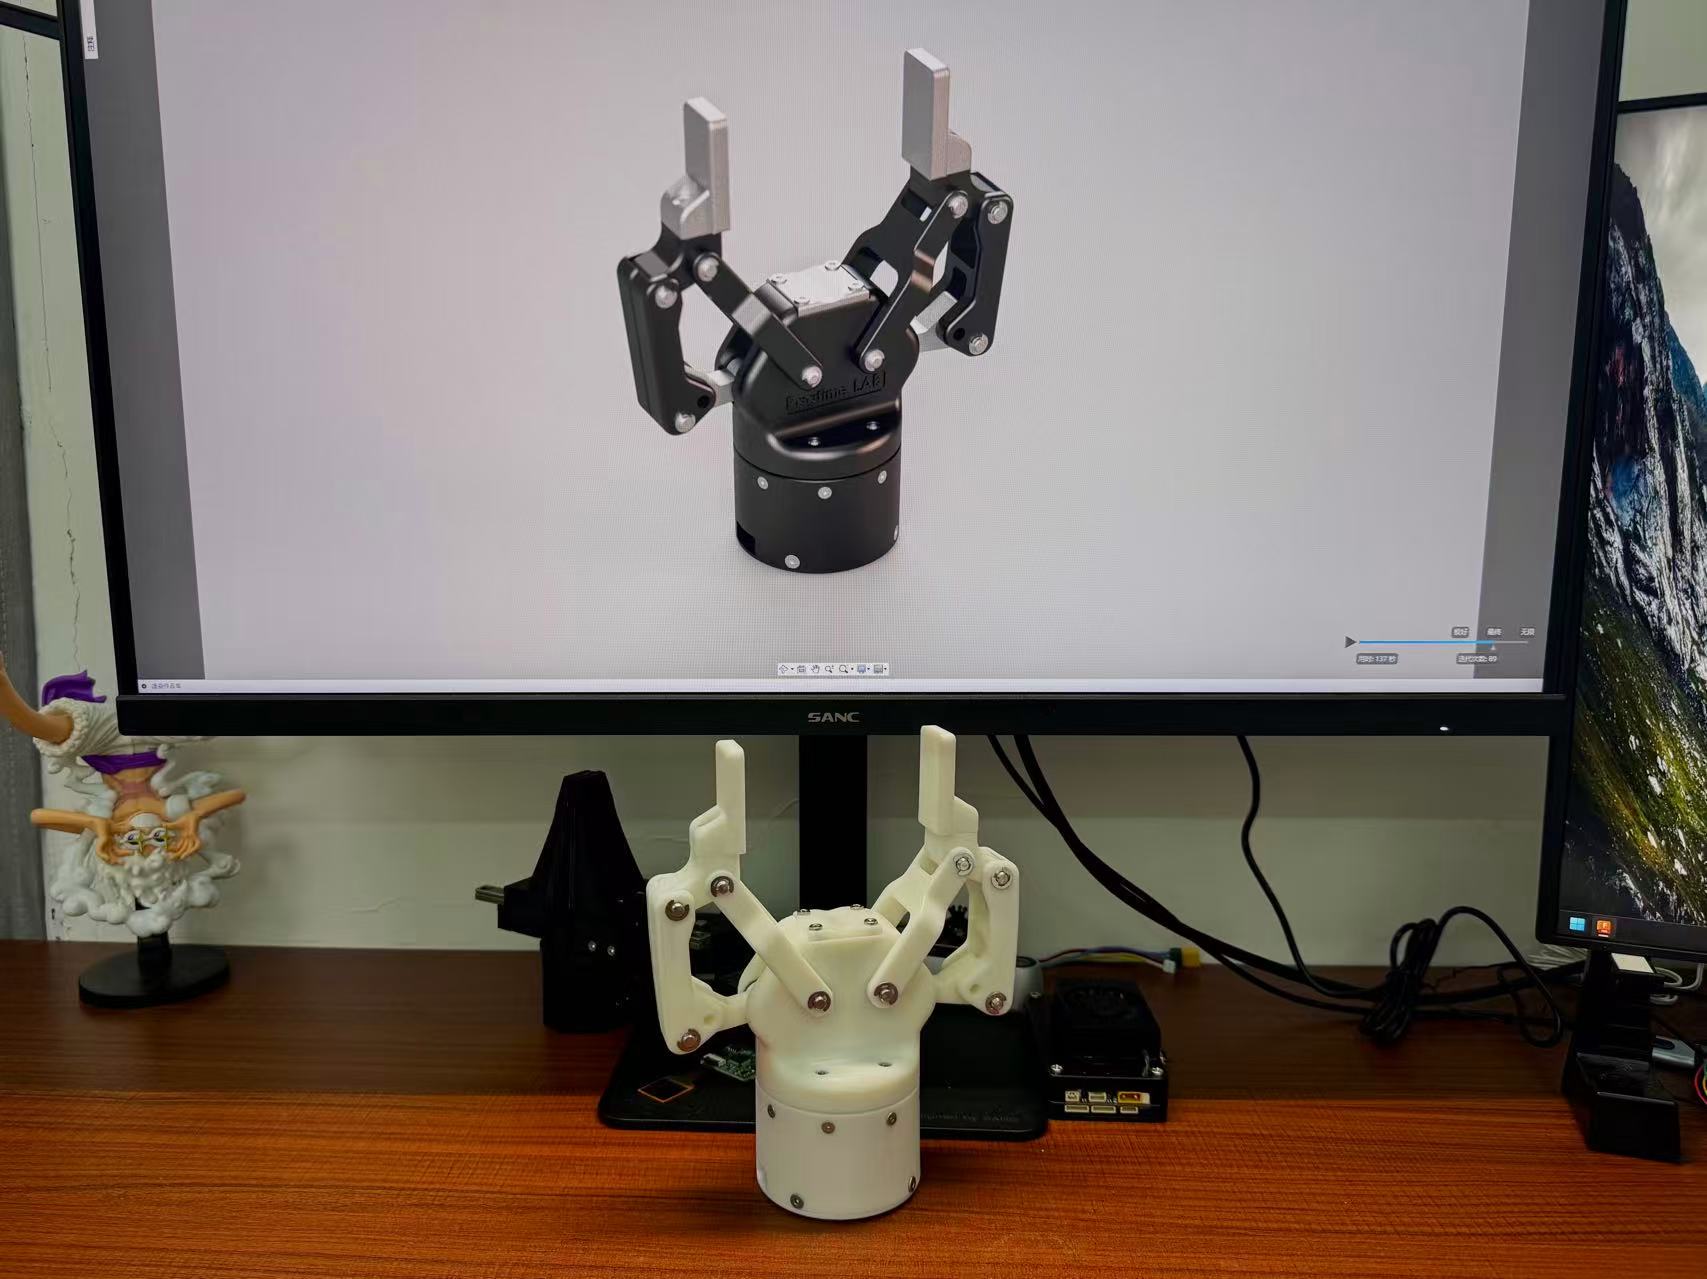
Underactuated two-finger gripper · End effector
Underactuated two-finger gripper with DM4310 actuation, assembly CAD and a mixed fabrication BOM; control licensing is unresolved.
Six-legged walking robot
A six-legged educational robot with printable chassis and legs, Dynamixel motors and Arduino control.
About USD 286.51 upstream estimate
Tool coupling and docking components · End effector
Tool-coupling hardware with dimensioned aluminum parts, a stepper-driven latch and V6/Hemera tool variants.
Robot-mounted two-finger gripper · End effector
DYNAMIXEL-driven two-finger gripper with a camera, assembly CAD and robot-specific mounting parts.
Parallel and adaptive grippers · End effector
XL430-W250-T drives a belt/rail gripper with constant-force springs; U2D2 and power hub are listed.
Dexterous hands · End effector
A five-finger tendon-driven hand with seven actuators, sixteen joints and separate hardware/software licenses.
Dexterous hands · End effector
Six-DoF anthropomorphic hand with linkage fingers, adaptive thumb and worm-and-rack transmissions.
Paste and syringe extrusion · End effector
A modular syringe pump and extrusion design with printable parts and multiple syringe and mounting configurations.
Dexterous hands · End effector
A printable four-finger hand with eight actuators and a Reachy 2 wrist interface.
From EUR 116.89 upstream estimate
Pellet extrusion · End effector
Large-format pellet screw extrusion around a purchased RobotDigg 16 mm compression screw/barrel and NEMA23 flange.
Dexterous hands · End effector
Printable CRAFT Hand parts and Bambu print profiles with left/right palm and thumb alternatives.
Delta tooling · End effector
A family of fourth-axis jaw grippers, flexible jaws, single/double suction heads, pen tools and a filament-printing head.
Delta tooling · End effector
Magnetic pick-and-place tool carried by the Delta-Robot One moving platform.
Dexterous hands · End effector
A tendon-driven hand with wrist and forearm; v1 build modifications differ from the v2 early-access design.
Pellet extrusion · End effector
Pellet extruder with multiple STEP revisions and NEMA17/NEMA23 variants, intended for MIM printing materials.
Suction and sensing · End effector
A suction cup combining vision and tactile sensing with wireless electronics.
Electric grippers · End effector
A printable replacement gripper for SO-101 that reuses the original gripper motor.
Dexterous hands · End effector
Six linear actuators drive five fingers with coupled joints; NUCLEO-F303K8 control, Bluetooth and ROS support.
Tool changing · End effector
Kinematic tool-changing ecosystem including extrusion and pen tools; liquid-handling use is reported.
Dexterous hands · End effector
An anthropomorphic hand with Full and Lite motor options and separate CAD downloads.
Paste and syringe extrusion · End effector
Compact syringe plunger driven by an NPM PFCL25-48Q4 linear stepper; printed parts optimized for ABS.
Vacuum and small-part handling · End effector
A vacuum pick-and-place nozzle subsystem with inventoried FreeCAD holder and spring files and separate purchased-component references.
Parallel and adaptive grippers · End effector
Two AX-12A servos drive parallel fingers through four-bar linkages; OpenRB-150 control and a palm RealSense D405.
Electric grippers · End effector
A modular stepper-driven gripper with selectable rail and motor lengths.
Dexterous hands · End effector
Tendon-driven hand family with base, touch, lite and joint-sensing variants; Feetech and Dynamixel motor-specific parts.
Paste and syringe extrusion · End effector
Modified Replistruder 5 with NEMA17, 3:1 GT2 belt reduction, anti-backlash TR8×1.5 lead screw and 1 mL Hamilton syringe.
Parallel and adaptive grippers · End effector
Printed parallel fingers with interchangeable tips and a Feetech STS3215; optional camera mount.
Pellet extrusion · End effector
A pellet-printing design for an Ender-3 conversion, with inventoried screw, barrel and heat-block geometry.
Parallel and adaptive grippers · End effector
Parallel gripper using the WHJ03 joint module, interface PCB and 24 V RS485/Modbus RTU control.
Paste and syringe extrusion · End effector
Syringe extrusion design for FRESH hydrogel printing, distributed as STL and STP in a versioned Zenodo archive.
Electric grippers · End effector
A parallel gripper for SO-ARM100/101 with selectable guide rods and modular printed parts.
Dexterous hands · End effector
A learned-control humanoid hand with external fabrication instructions, CAD and controller data.
Parallel and adaptive grippers · End effector
Tendon-driven sliding jaws on a 12 mm rail, MX28T servo, OpenCM9 and EXP485. Optional capacitor board supports power-loss repositioning.
Soft grippers · End effector
A pneumatic soft gripper made with cast elastomer and printed molds.
Electric grippers · End effector
A motor-driven adaptive gripper with a reported 48 mm stroke and CAN control.
About EUR 773.50 vendor price
Filament extrusion · End effector
Filament toolhead platform with CAD and printable housings for a printer extrusion assembly.
Adaptive grippers · End effector
A family of adaptive hands with shared CAD parts and a separate Dynamixel control repository.
Dexterous hands · End effector
Yeah Hand/Rebelia lineage: humanlike hand with separate robot/prosthetic firmware and commercial servos.
Two leader arms and two follower arms
A four-arm bimanual teleoperation and demonstration-recording system with a separate learning stack.
Six-axis articulated arm
A six-axis workshop arm with printed or aluminum structure; this review covers MK3 and its matching 6.3-series controls.
Biped humanoid
A 1.2 m humanoid design with separate media and motion computers, fabricated metal/nylon structure and an unfinished locomotion-policy release.
Printed articulated arm
A printed educational robot arm with CAD, firmware, BOM and assembly documents in one source repository.
Printed-gearbox humanoid
A humanoid built around printed gearboxes, with separate simulation assets and low-level control code that requires joint calibration after power cycles.
From USD 3,349.90 Known US parts subtotal · Oct 4, 2026
Legged robots & hardware
A six-actuator research biped with passive ankles, tethered power/data and no active yaw control.
Compact articulated arm
A compact custom arm combining CNC parts, harmonic reducers and custom motor-control electronics.
Desktop articulated arm
A six-axis printed arm built around cycloidal gearboxes, with separate mechanical and control documentation.
Humanoids
A humanoid development project with a separate arm-and-exoskeleton branch of work for LeRobot teleoperation.
Humanoids
A research humanoid family whose hardware revisions, robot configuration and software distribution must be matched before reproduction.
Humanoids
A humanoid soccer research platform with a released load-bearing plastic body design and a separately maintained ROS framework.
Humanoids
A modular printable humanoid with body-section tutorials, tendon-driven hands and a separate MyRobotLab control route.
Modular humanoid
A public-alpha humanoid project whose CAD, operating system, simulation and inference code live in separate sources.
Desktop robot arm
A printable Dynamixel arm with a separate leader design for teleoperation and robot-learning experiments.
From USD 245.85 Known US parts subtotal · Oct 4, 2026
Laser-cut articulated arm
A four-degree-of-freedom educational arm made from versioned laser-cut parts.
Compact printed humanoid
A roughly 30 cm printed humanoid using 19 DYNAMIXEL servos, a Raspberry Pi Zero 2 W and a custom-fabricated robot HAT.
From USD 585.27 Known US parts subtotal · Oct 4, 2026
Humanoid interaction platform
A humanoid interaction research platform with distinct FDM and SLS-oriented mechanical designs and a separate software repository.
Humanoids
Two humanoid soccer research designs with separate CAD, actuator selections and fabrication requirements.
Printed articulated arm
Printable Niryo One arm designs with a separate ROS stack and a documented older-hardware archive.
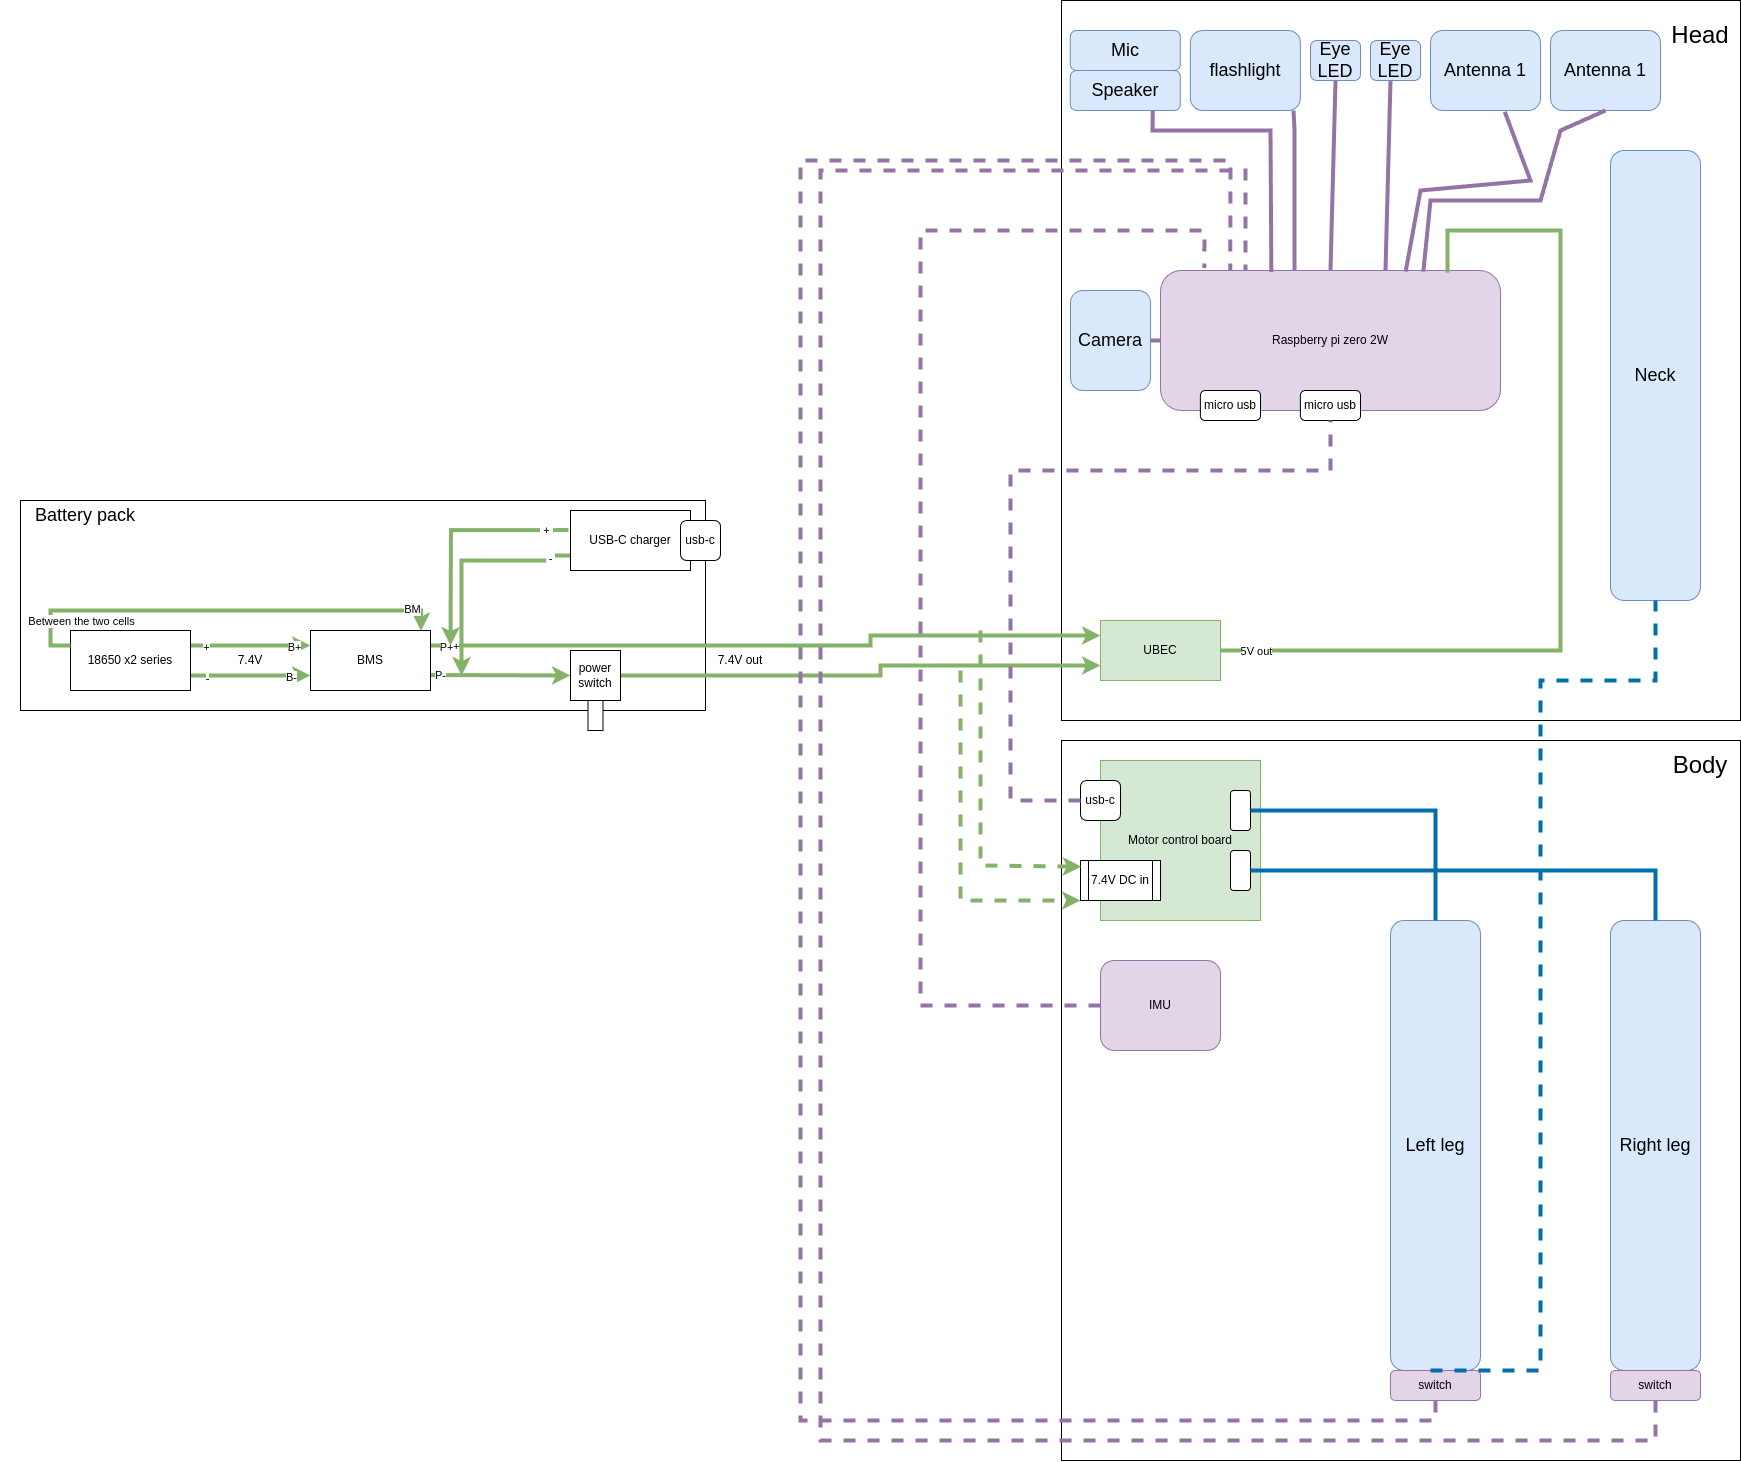
Legged robots & hardware
A small printed biped with bus servos, a Raspberry Pi runtime and learned walking policies; the reviewed v2 build still has documentation and configuration gaps.
Articulated arm platform
An arm research platform whose hardware release separates the arm, evaluation cell and KER assemblies.
Four-joint arm with actuated gripper
A four-joint DYNAMIXEL arm with a separate gripper axis, documented for PC-based ROS control or standalone OpenCR operation.
Printed desktop arm
A printed desktop arm with a separate Commander application and a required PAROL6 control board.
Humanoids
A printable humanoid whose #5 basic design replaces the #4 part set and uses Raspberry Pi 5 compute.
Six-axis articulated arm
A six-axis research arm using Dynamixel MX-28 motors and Python control.
Six-axis educational arm
A six-axis educational arm using printable parts, Dynamixel XL-320 servos and Raspberry Pi control.
Printed humanoid
A printed research humanoid using 25 Dynamixel actuators and a documented legacy Odroid setup.
Humanoid platform
A Reachy 2 ROS 2 workspace providing robot descriptions, control interfaces and simulation launch components.
Expressive desktop robot
An expressive desktop robot with separate Wireless, USB-connected Lite and simulation setup routes.
Biped humanoid
A 20-joint research humanoid with a 2025 ROS 2 revision and an older ROS 1 software lineage that must be kept distinct.
Legged robots & hardware
A modular torque-controlled quadruped family; this review distinguishes wired Solo12 from its battery-and-wireless upgrade.
Legged robots & hardware
A historical eight-actuator quadruped using coaxial leg mechanisms, Teensy control and customized ODrive firmware.
Original Pupper v1 servo-driven quadruped
The original servo-driven Stanford Pupper, a Raspberry Pi quadruped whose upstream support has ended in favor of a separate v3 design.
Articulated six-axis arm
A printable six-degree-of-freedom teaching arm with editable FreeCAD, STEP and STL mechanical sources.
Printed research humanoid
A humanoid research platform with distinct 2XC and 2XM motor configurations, separate PCB sourcing and noncommercial hardware terms.
Six-axis articulated arm
A family of six-axis YAM arms supported by a Python and CAN control library with revision-specific models.
Libraries · Software
Tools for collecting robot demonstrations and training and deploying learned policies.
Frameworks · Software
A ROS 2 manipulation framework supporting motion planning and kinematics.
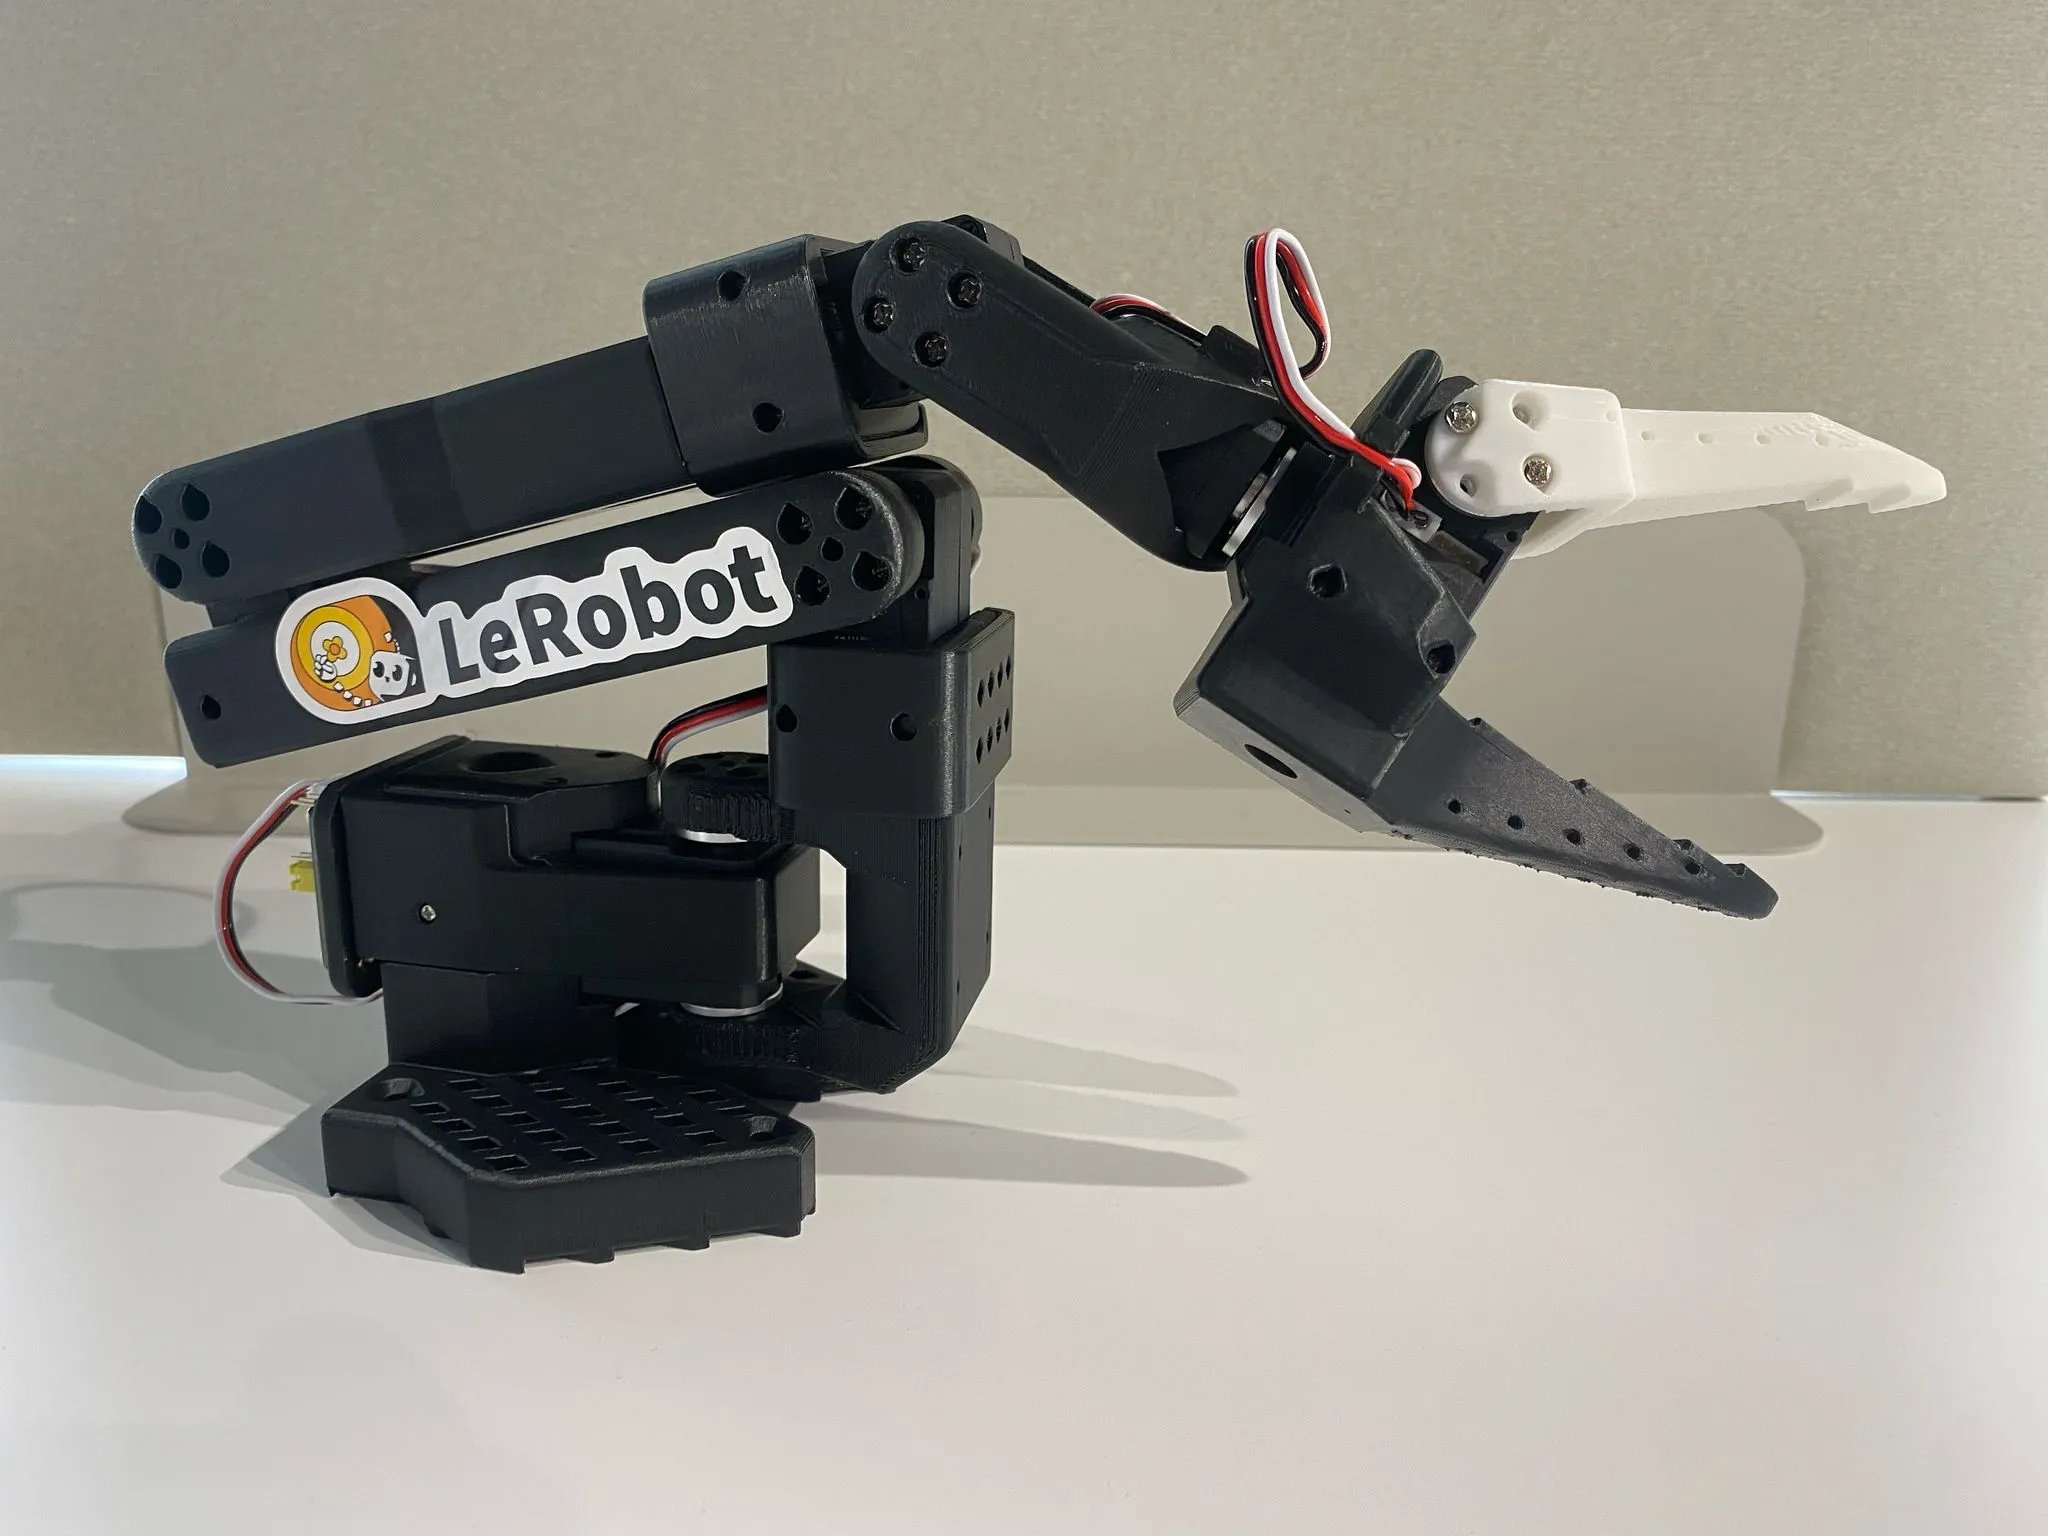
Desktop manipulator
A printable robot arm for teleoperation and robot-learning experiments.
From USD 150.28 Known US parts subtotal · Oct 4, 2026
Wheeled mobile platform
A mobile robot platform for learning and experimenting with navigation.
About USD 783.50 vendor price
No matching entries. Try another term or clear the filters.
We know about these designs but do not profile them. Each note says why. Follow the links for the official project and its license.
Platform tags identify documented interfaces or applications; they do not establish tested fit or certification. Methodology · About the spec